Yinzhe Zhou / Publications

Publications

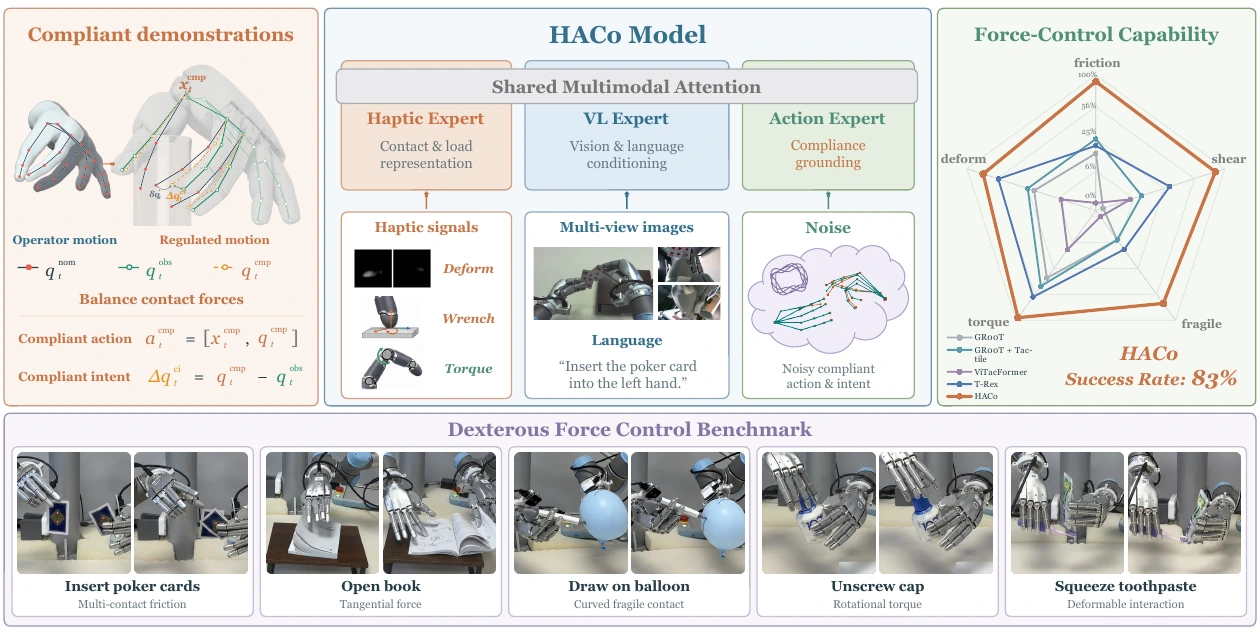
HACo overview showing compliant demonstrations, the haptic policy, and five robot tasks

arXiv preprint · 2026 · arXiv:2609.36596 ↗

HACo: Learning Haptic Active Compliance for Force-Aware Dexterous Manipulation

Naisheng Ye, Yinzhe Zhou, Junkai Zhao, Yuhang Lu, Checheng Yu, Zhenjie Yang, Pengwei Wang, Hongyang Li

A tactile-conditioned VLA policy for force-aware dexterous manipulation, achieving 83% mean success across five real-robot tasks.

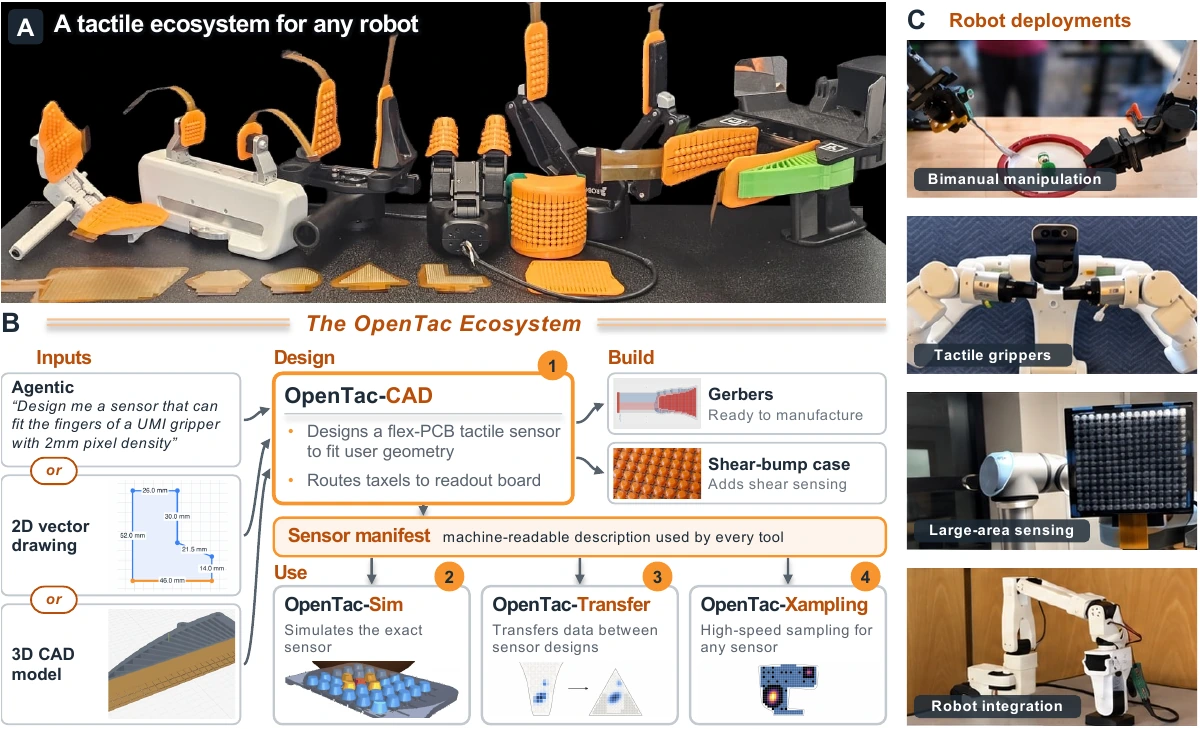
OpenTac overview showing tactile sensors, the design ecosystem, and robot deployments

Manuscript · 2026

OpenTac: An Open Ecosystem for Customizable, Scalable, and Transferable 3D Tactile Sensing

Ariel Slepyan, Geeta Chandra Raju Bethala, Jiafeng Gu, Anagha Rajendra Dangle, Yinzhe Zhou, Hongyuan Fu, Jade Sim, Tuhin Basu, Xinyi Yin, Md Faizal Karim, Gregory Hager, Homanga Bharadhwaj, Anand Bhattad, Krishna Murthy Jatavallabhula, Nitish V. Thakor

OpenTac presents customizable 3D tactile skins and tools for sensor design, simulation, cross-sensor transfer, and adaptive sampling.