HACo: Learning Haptic Active Compliance for Force-Aware Dexterous Manipulation
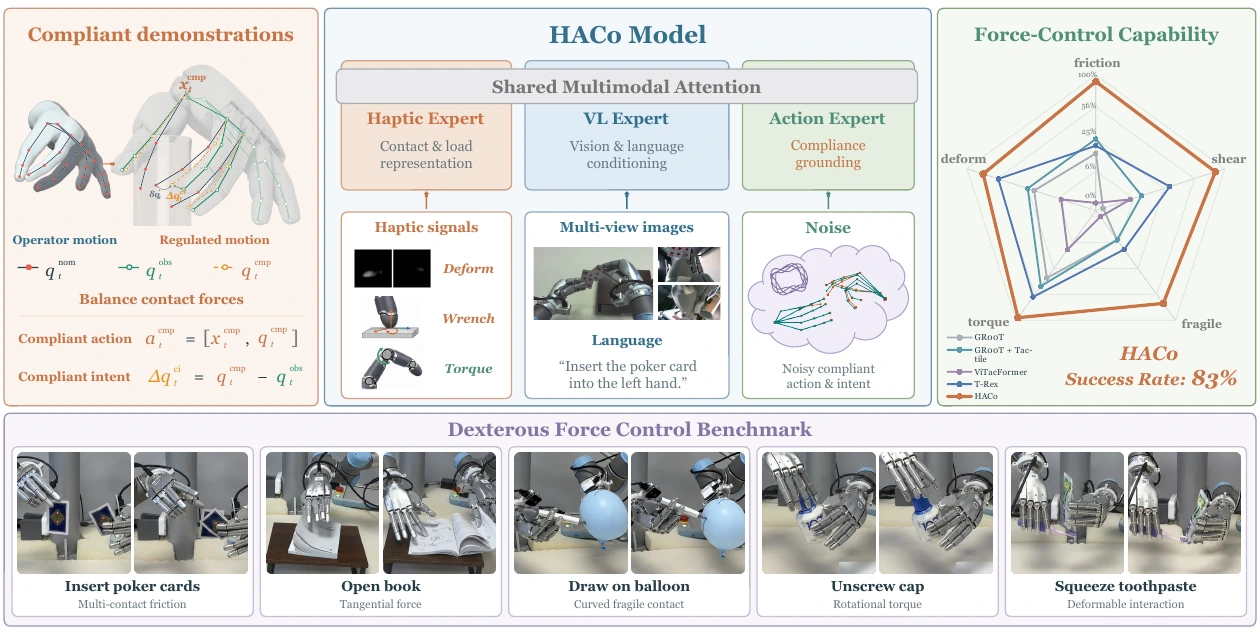
A tactile-conditioned VLA policy for force-aware dexterous manipulation, achieving 83% mean success across five real-robot tasks.
I'm an M.S. student in Electrical and Computer Engineering at Johns Hopkins University, working with Prof. Nitish V. Thakor in the Neuroengineering and Biomedical Instrumentation Laboratory.
I study tactile sensing and robot learning for contact-rich manipulation. My recent work includes shear-force simulation and robot experiments, event-based visuo-tactile imitation learning, and haptic feedback for dexterous manipulation. I plan to pursue a PhD in Fall 2027.
A tactile-conditioned VLA policy for force-aware dexterous manipulation, achieving 83% mean success across five real-robot tasks.
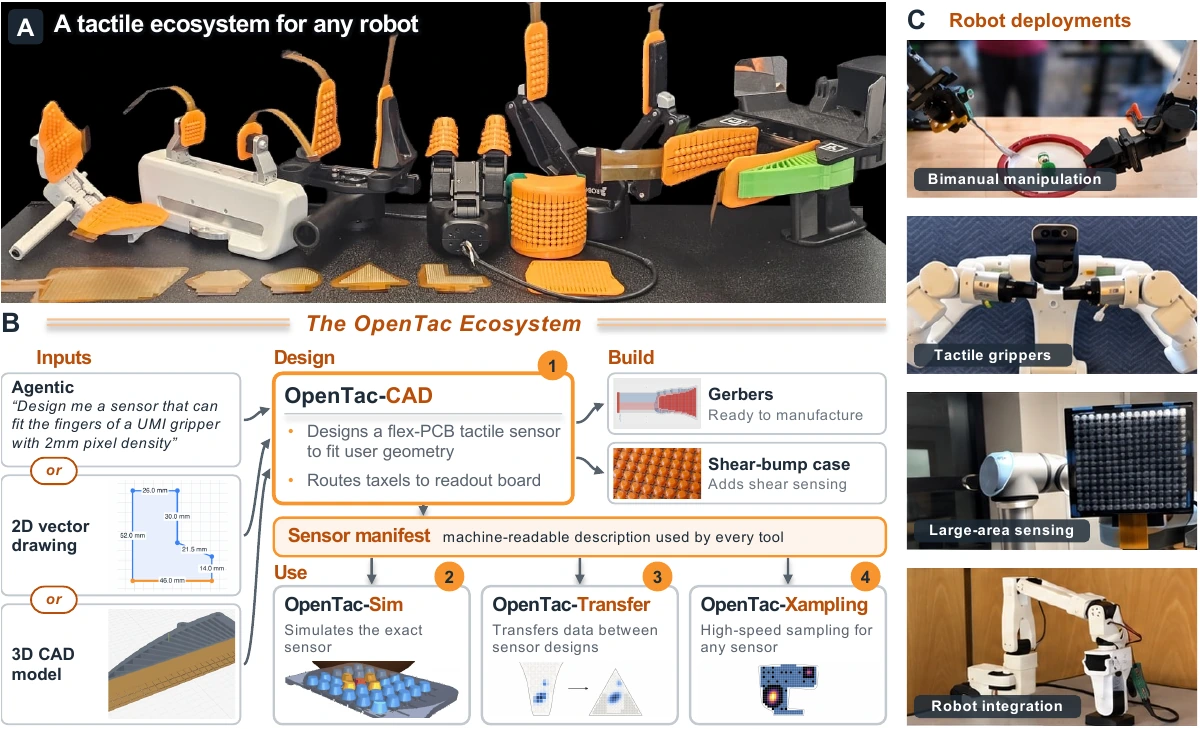
OpenTac presents customizable 3D tactile skins and tools for sensor design, simulation, cross-sensor transfer, and adaptive sampling.
Aug. 2025 – Present
Master of Science in Electrical and Computer Engineering
Baltimore, MD, USA
Aug. 2021 – May 2025
Bachelor of Science in Electrical and Computer Engineering
Macao SAR
Jan. 2023 – Aug. 2023
Exchange Student, Department of Electrical Engineering
Hong Kong SAR
Nov. 2025 – Present
Event-Based Visuo-Tactile Sensing for Robot Imitation Learning
Building a synchronized RGB, tactile, and event-based imitation-learning pipeline for contact-rich robot manipulation.
Jun. 2026 – Sep. 2026
HACo: Haptic Active Compliance for Dexterous Manipulation
Built compliant teleoperation and a tactile-conditioned VLA policy for dexterous manipulation, achieving 83% mean success across five real-robot tasks.
Feb. 2026 – Sep. 2026
OpenTac: Shear-Force Simulation and Robot Experiments
Built Isaac Sim shear-force simulations and ran sensor characterization and robotic grasping experiments for the OpenTac 3D tactile sensing project.
Sep. 2024 – May 2025
Singular Spectrum Analysis for Biosignal Denoising and Feature Extraction
Developed a two-level Singular Spectrum Analysis method to denoise ECG and EEG signals and recover physiological features.
Jun. 2024 – Sep. 2024
Fine-Tuning Mixtral 8x7B on Biochemical Molecular Data
Fine-tuned Mixtral 8x7B for molecular property prediction using PubChem data and SMILES-neighbor retrieval, improving test accuracy from 67% to 77%.
May 2023 – Aug. 2023
Neural Decoding for Implantable Brain–Machine Interfaces with ANN and SNN
Benchmarked ANN and SNN decoders on primate neural recordings for implantable brain–machine interfaces.
May 2022 – Jul. 2022
FPGA-Based Hardware Time-Triggered System for Biomedical Engineering
Implemented FPGA signal conditioning and a deterministic time-triggered architecture for biomedical data acquisition.
Aug. 31 – Dec. 23, 2026
Hands-on Robot Learning (EN.601.498.01.FA26)
Course assistant for Hands-on Robot Learning, taught by Krishna Murthy Jatavallabhula.